
Explore the PID Controller Tuning Lab
Tune proportional, integral and derivative gains on a real first-order plant, watch the closed-loop step response redraw with a sweeping time marker.
- Free to use
- No signup
- Nothing to install
- Runs in your browser
Illustration. Open the tool for the real thing.
See it in action
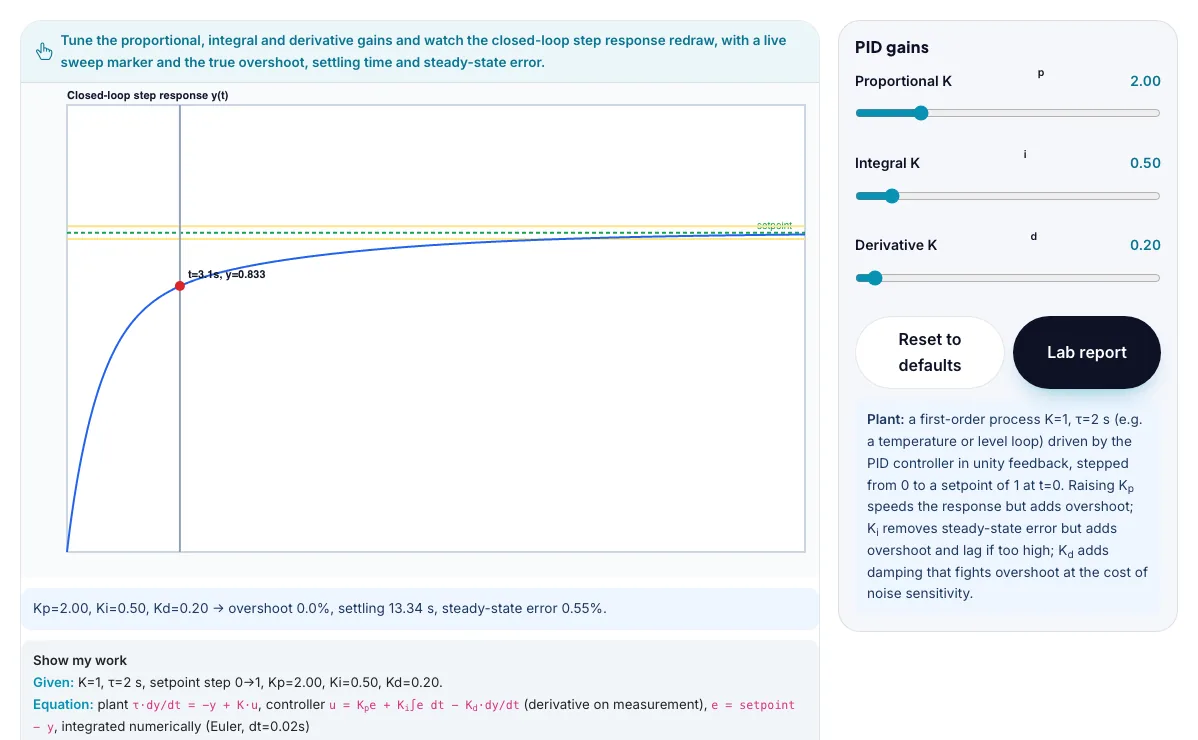
The PID Controller Tuning Lab with sample data entered and the result showing.
What is the PID Controller Tuning Lab?
Tune proportional, integral and derivative gains on a real first-order plant, watch the closed-loop step response redraw with a sweeping time marker, and read off the true overshoot, settling time and steady-state error. It runs in your browser, so a change to a setting or a drag on an object shows up at once.
Control engineers tune exactly these three gains on real temperature loops, flow loops, motor speed controllers, drone stabilization and robotic arm position control, balancing response speed against overshoot and steady-state accuracy.
3 steps to your result
Open the tool and follow along. Nothing to install.
What you get
A PID controller drives a plant using u = Kp·e + Ki·∫e dt + Kd·de/dt, where e is the error between setpoint and measured output.
Raising Kp alone speeds up the response and shrinks steady-state error, but too much Kp causes overshoot and eventually oscillation.
Integral action (Ki) is the only term that can drive steady-state error to exactly zero, because it keeps accumulating as long as any error remains - but too much Ki adds overshoot and lag ('integral windup').
Try the well-damped challenge: overshoot below 10%, settling time below 10 s.
Try the integral-action challenge: steady-state error below 1% while keeping overshoot below 25%.
Push Kp very high alone and watch the oscillation grow.
Used for
Pick one to see how it fits.
Engineering learners
Engineering and technology students, makers, robotics clubs and teachers of design and technology.
Try it freeTeachers
For teachers: project the PID Controller Tuning Lab on the board, let students predict the result, then run it together and test this: Try the integral-action challenge: steady-state error below 1% while keeping overshoot below 25%. For students: change one thing at a time and write down what changes.
Try it freeHow it compares
A plain look at this tool next to the usual alternative.
| This simulation | Textbook diagram | |
|---|---|---|
| Interactive | Drag, tap and change settings | Fixed picture |
| Install | Nothing to install | Not needed |
| Cost | Free to use | Depends on the book |
Questions people ask
Why does proportional control alone almost always leave a steady-state error on this kind of plant?
With pure proportional control, the controller output is u=Kp·e, and at steady state y settles wherever e becomes just small enough that Kp·e·K exactly balances the plant's natural decay - since e can never reach exactly zero without a control action to sustain it, a permanent offset (steady-state error) remains unless integral action is added to keep pushing once error is small.
Why can adding too much integral gain actually make the response worse instead of better?
Integral action keeps accumulating even while the output is overshooting toward the setpoint, so by the time the output arrives at the setpoint the accumulated integral term is still pushing it further, causing it to overshoot and then have to unwind that same accumulated term before it can settle - producing larger overshoot and a longer, more oscillatory settling process.
Is the PID Controller Tuning Lab free to use?
Yes. The PID Controller Tuning Lab is free, needs no signup or download and runs in your web browser. It is part of the Engineering group of AZRS simulations.
Does the PID Controller Tuning Lab work on a phone or tablet?
Yes. The PID Controller Tuning Lab takes touch input as well as mouse input, so you can use its 3 adjustable settings with a finger. A larger screen makes the controls and graphs easier to read.
How do I use the PID Controller Tuning Lab?
1. In the PID Controller Tuning Lab, use the controls to change Proportional Kp, Integral Ki, Derivative Kd. The simulation reacts instantly. 2. Start with this experiment: Try the well-damped challenge: overshoot below 10%, settling time below 10 s. Drag any glowing handle, object or slider with your mouse or finger and the PID Controller Tuning Lab responds in real time. 3. Change one setting at a time and watch which readout moves, then compare it with this idea: A PID controller drives a plant using u = Kp·e + Ki·∫e dt + Kd·de/dt, where e is the error between setpoint and measured output.
More free tools
Related to the PID Controller Tuning Lab.
Try the PID Controller Tuning Lab now
Tune proportional, integral and derivative gains on a real first-order plant, watch the. Free to use.
Try it free